IROS 2022
A Two-Stage Learning Architecture That Generates High-Quality Grasps for a Multi-Fingered Hand
Dominik Winkelbauer Berthold Bäuml Matthias Humt Nils Thuerey Rudolph Triebel
Abstract
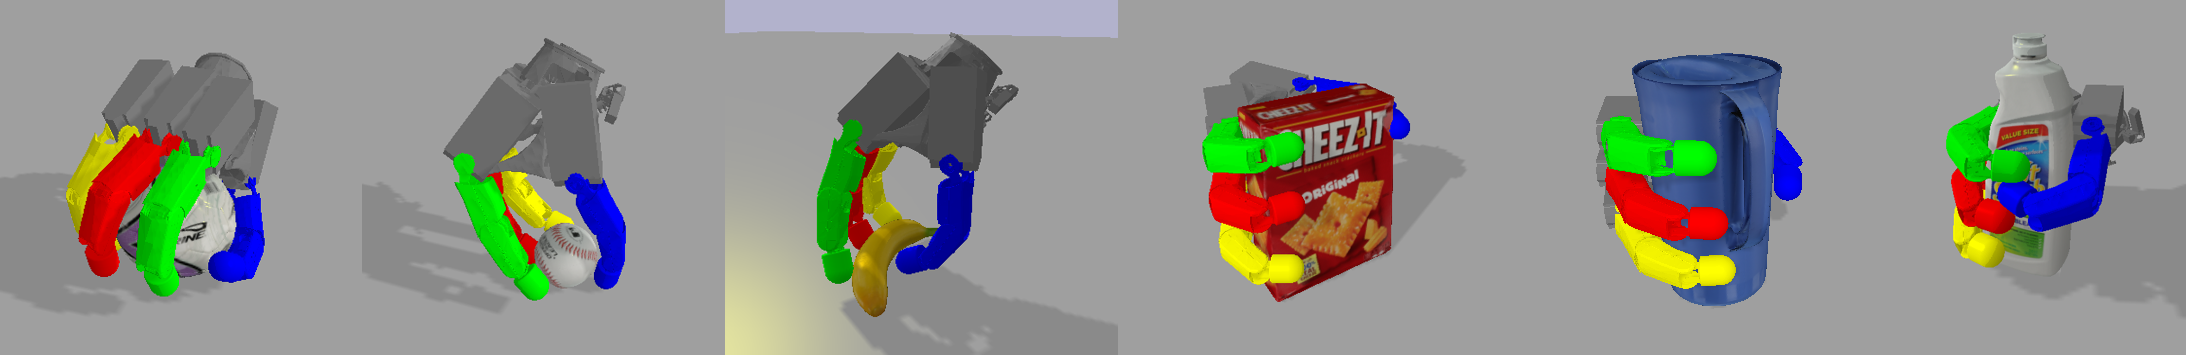
In this work, we investigate the problem of planning stable grasps for object manipulations using an 18-DOF robotic hand with four fingers. The main challenge here is the high-dimensional search space, and we address this problem using a novel two-stage learning process. In the first stage, we train an autoregressive network called the hand-pose-generator, which learns to generate a distribution of valid 6D poses of the palm for a given volumetric object representation. In the second stage, we employ a network that regresses 12D finger positions and scalar grasp qualities from given object representations and palm poses. To train our networks, we use synthetic training data generated by a novel grasp planning algorithm, which also proceeds stage-wise: first the palm pose, then the finger positions. Here, we devise a Bayesian Optimization scheme for the palm pose and a physics-based grasp pose metric to rate stable grasps. In experiments on the YCB benchmark data set, we show a grasp success rate of over 83%, as well as qualitative results on real scenarios of grasping unknown objects.
Cite this paper as:
@inproceedings{Winkelbauer2022,
    author = {Dominik Winkelbauer and Berthold B{\"a}uml and Matthias Humt and Nils Thuerey and Rudolph Triebel},
    booktitle = {IEEE International Conference on Intelligent Robots and Systems},
    title = {A Two-Stage Learning Architecture That Generates High-Quality Grasps for a Multi-Fingered Hand},
    year = {2022}}